RoboCar 4.0
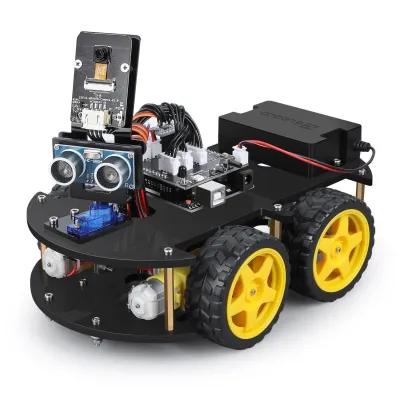
A browser-controlled robot car, joining live video and real-time commands.
- Scope
- Independent work / Robotics
- Period
- 2024
- Role
- Full-stack & hardware
- Tools
- ESP32 · Python · WebSockets · Arduino
Context
This personal experiment explores how a web interface, backend and microcontrollers can form a responsive control loop for a physical car.
My contribution
- Used WebSockets to send control commands and receive updates in real time.
- Connected an ESP32 and Python backend to an Arduino motor controller using JSON messages.
- Brought a live camera stream into the browser alongside the controls.